XDOF Alternative for Robotics Data Collection
Looking for robotics training data? Encord is the top XDOF alternative for egocentric, embodied, and sensor data collection.
XDOF Alternative for Robotics Data Collection
Looking for robotics training data? Encord is the top XDOF alternative for egocentric, embodied, and sensor data collection.
Evaluating alternatives to XDOF data collection? Partnering with Encord gives you access to vetted domain experts specific to your embodiment, dedicated lab facilities, and bespoke protocol design for your robots.
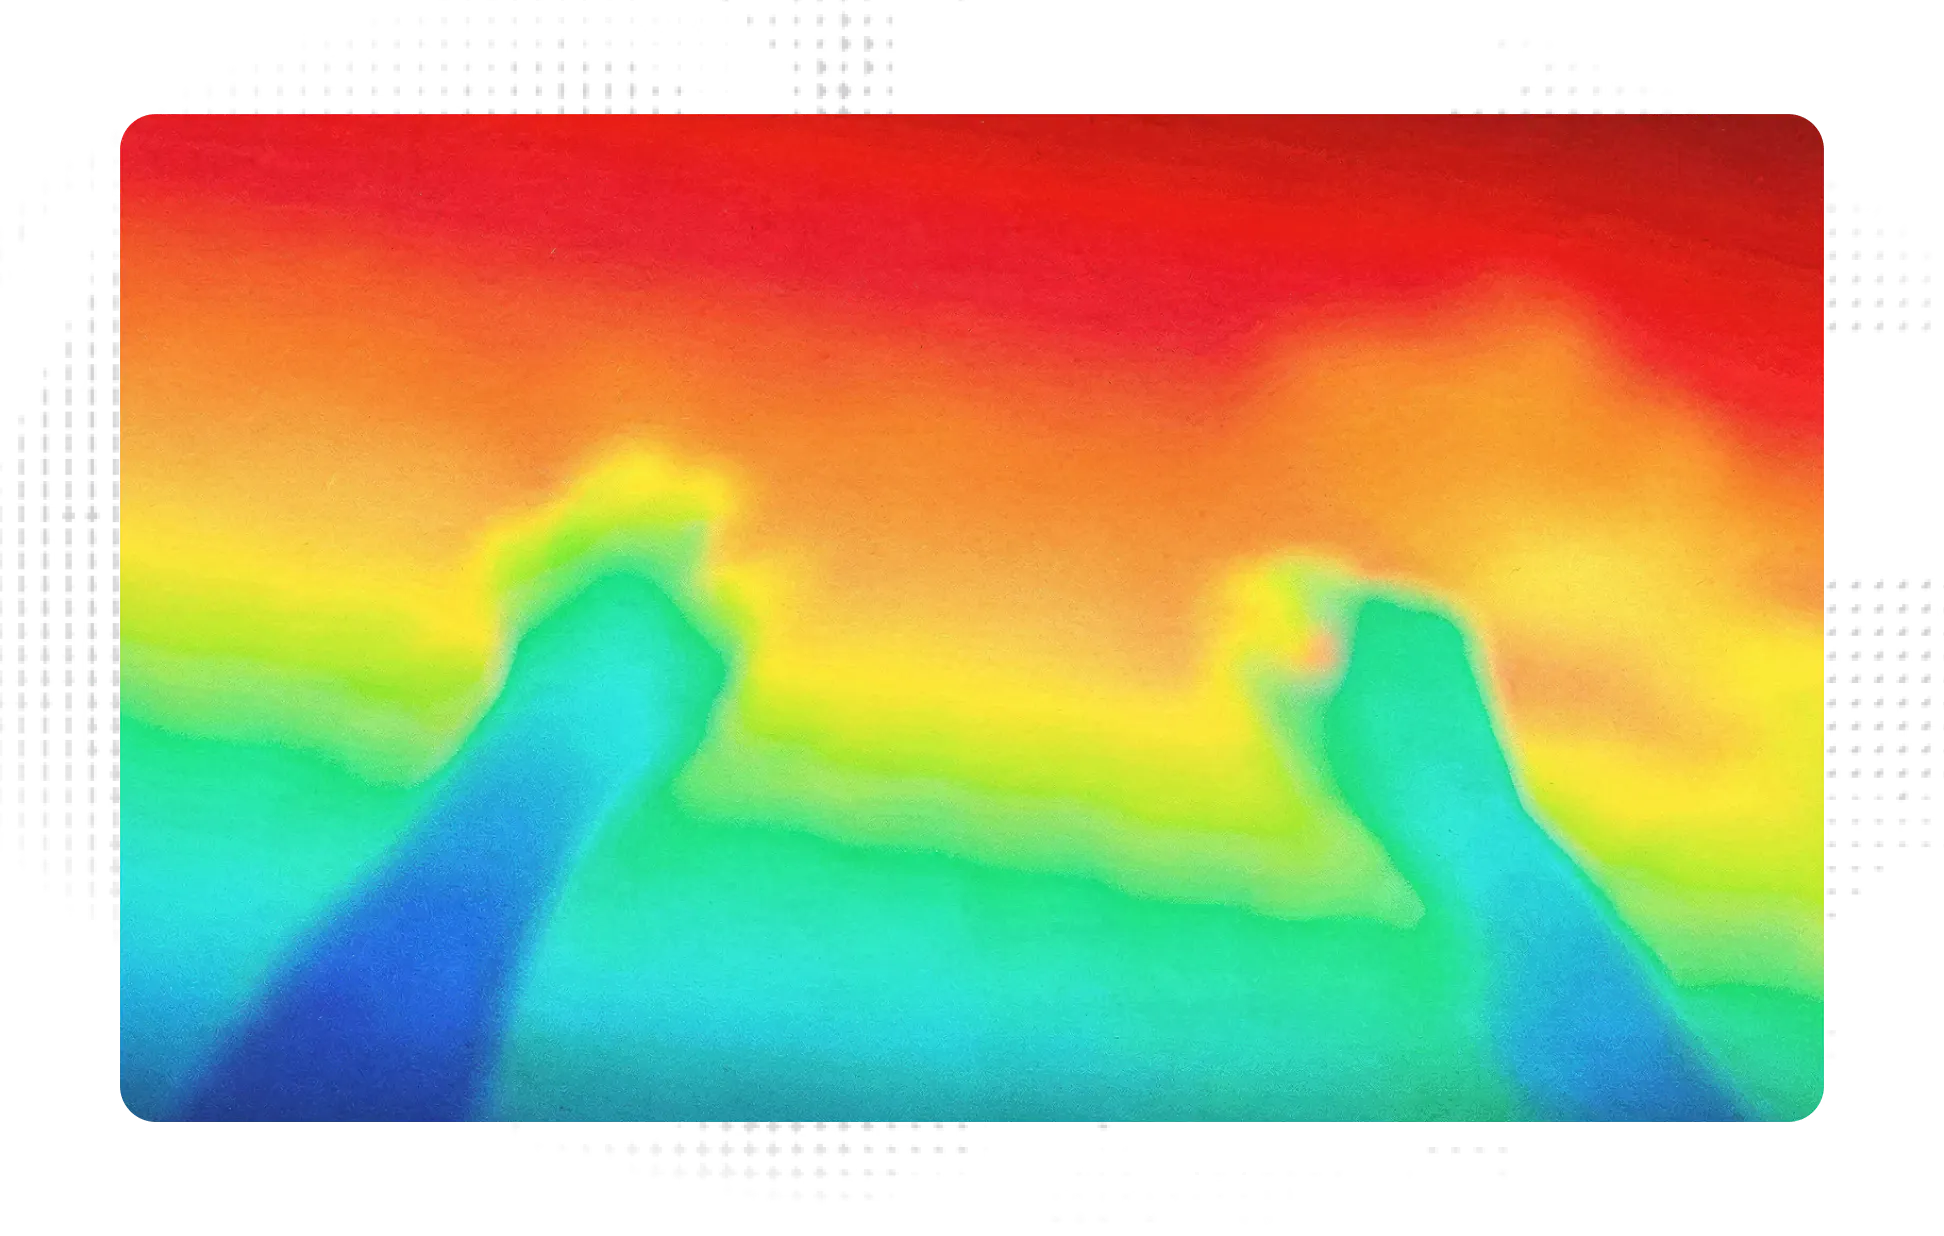
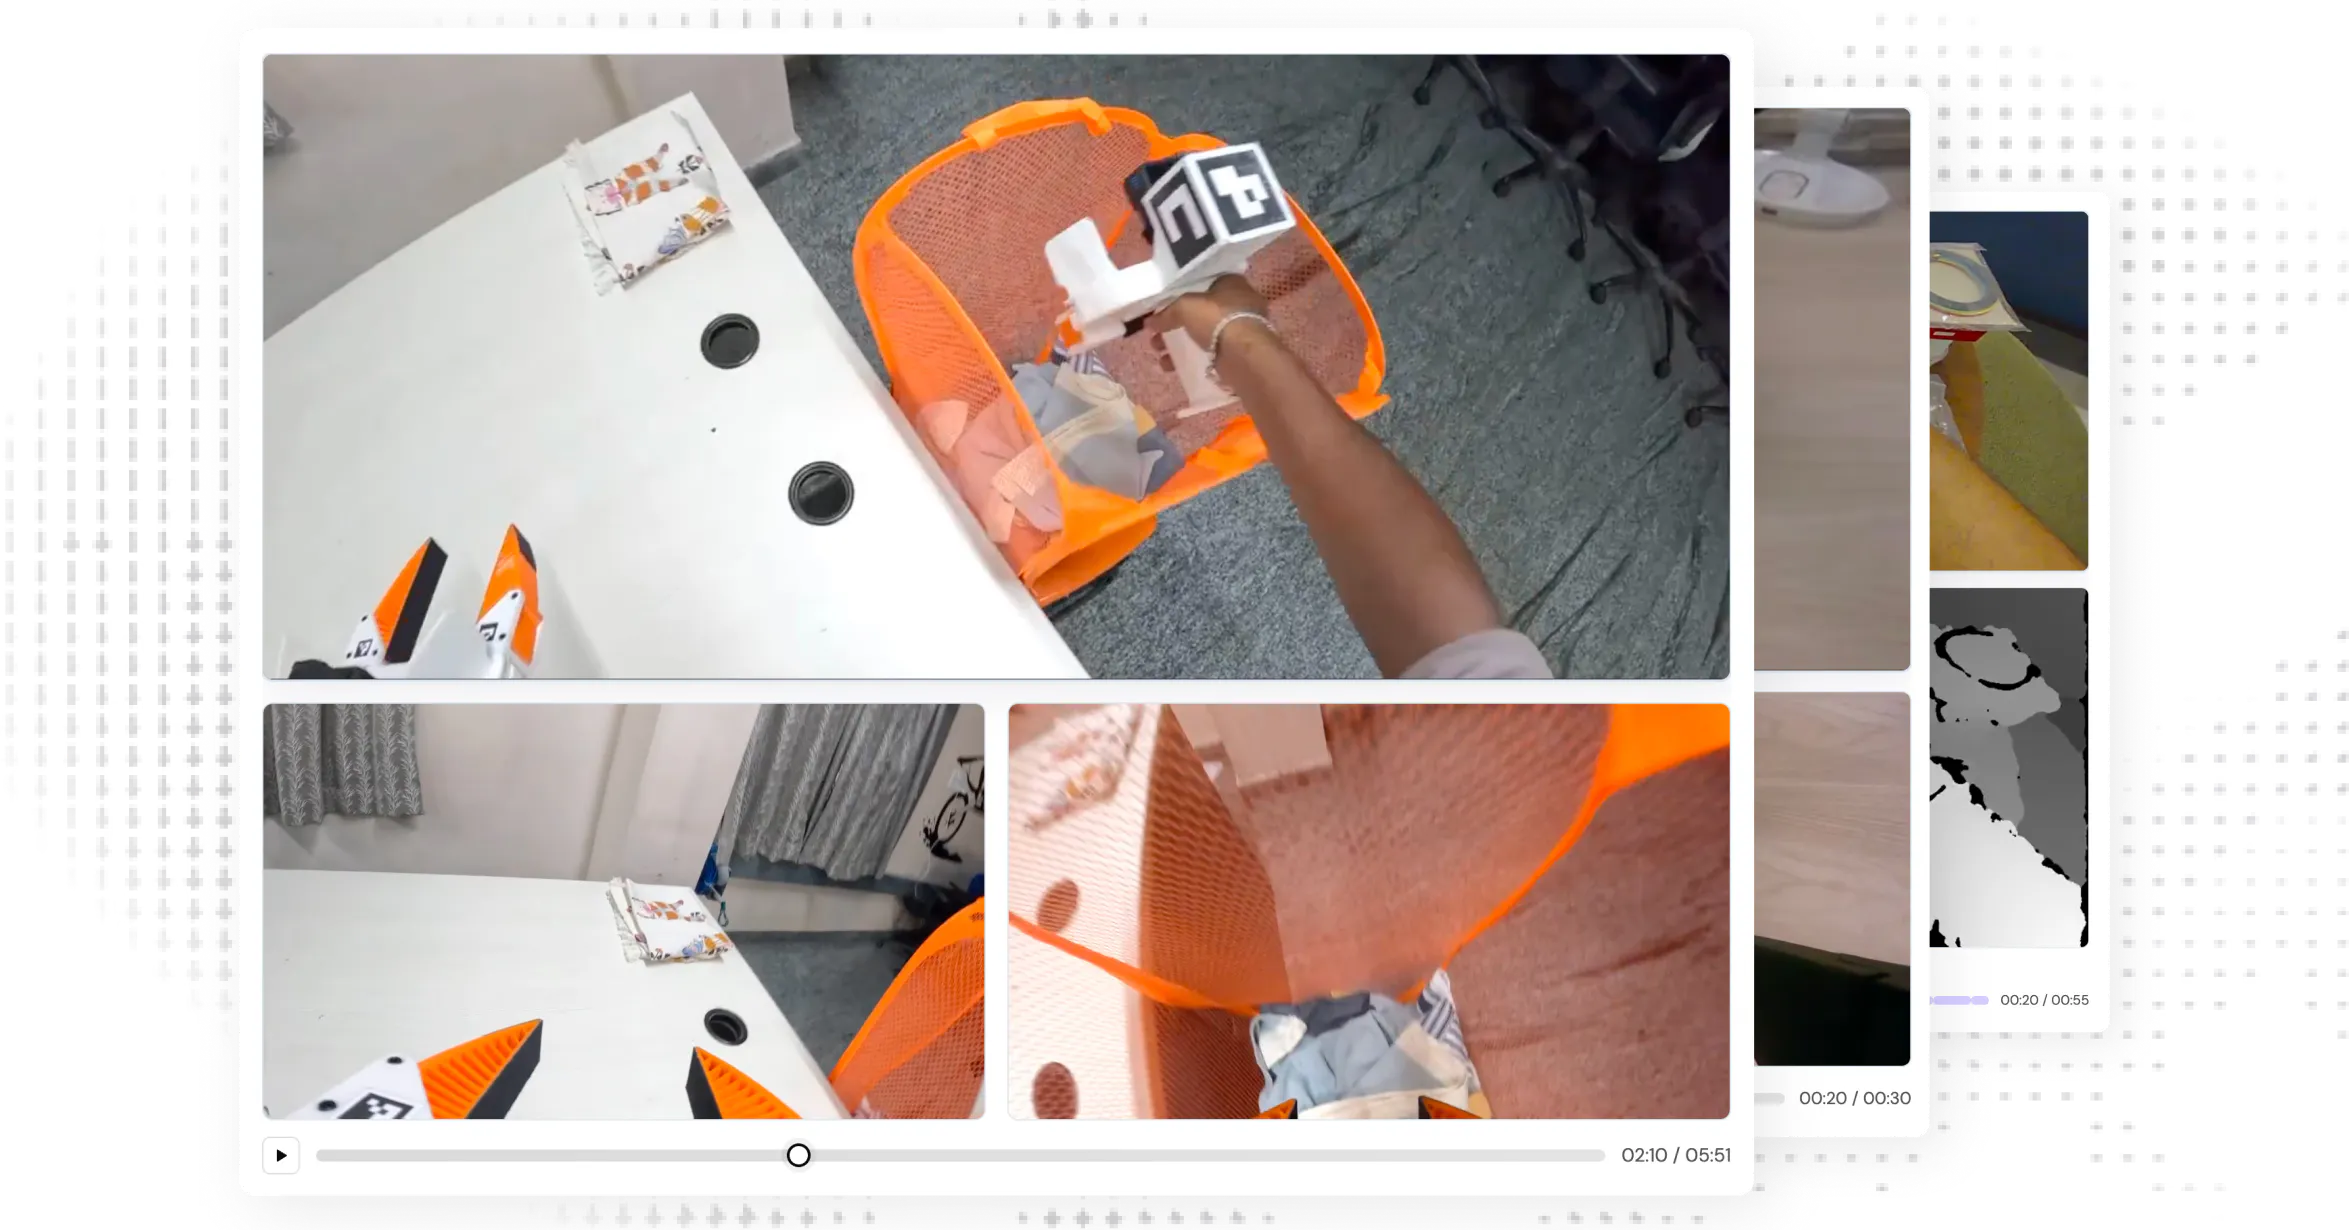
First-person video & sensor data of humans performing tasks in household, industrial, and commercial environments. Collected using head & wrist cameras at 1080p/30FPS.
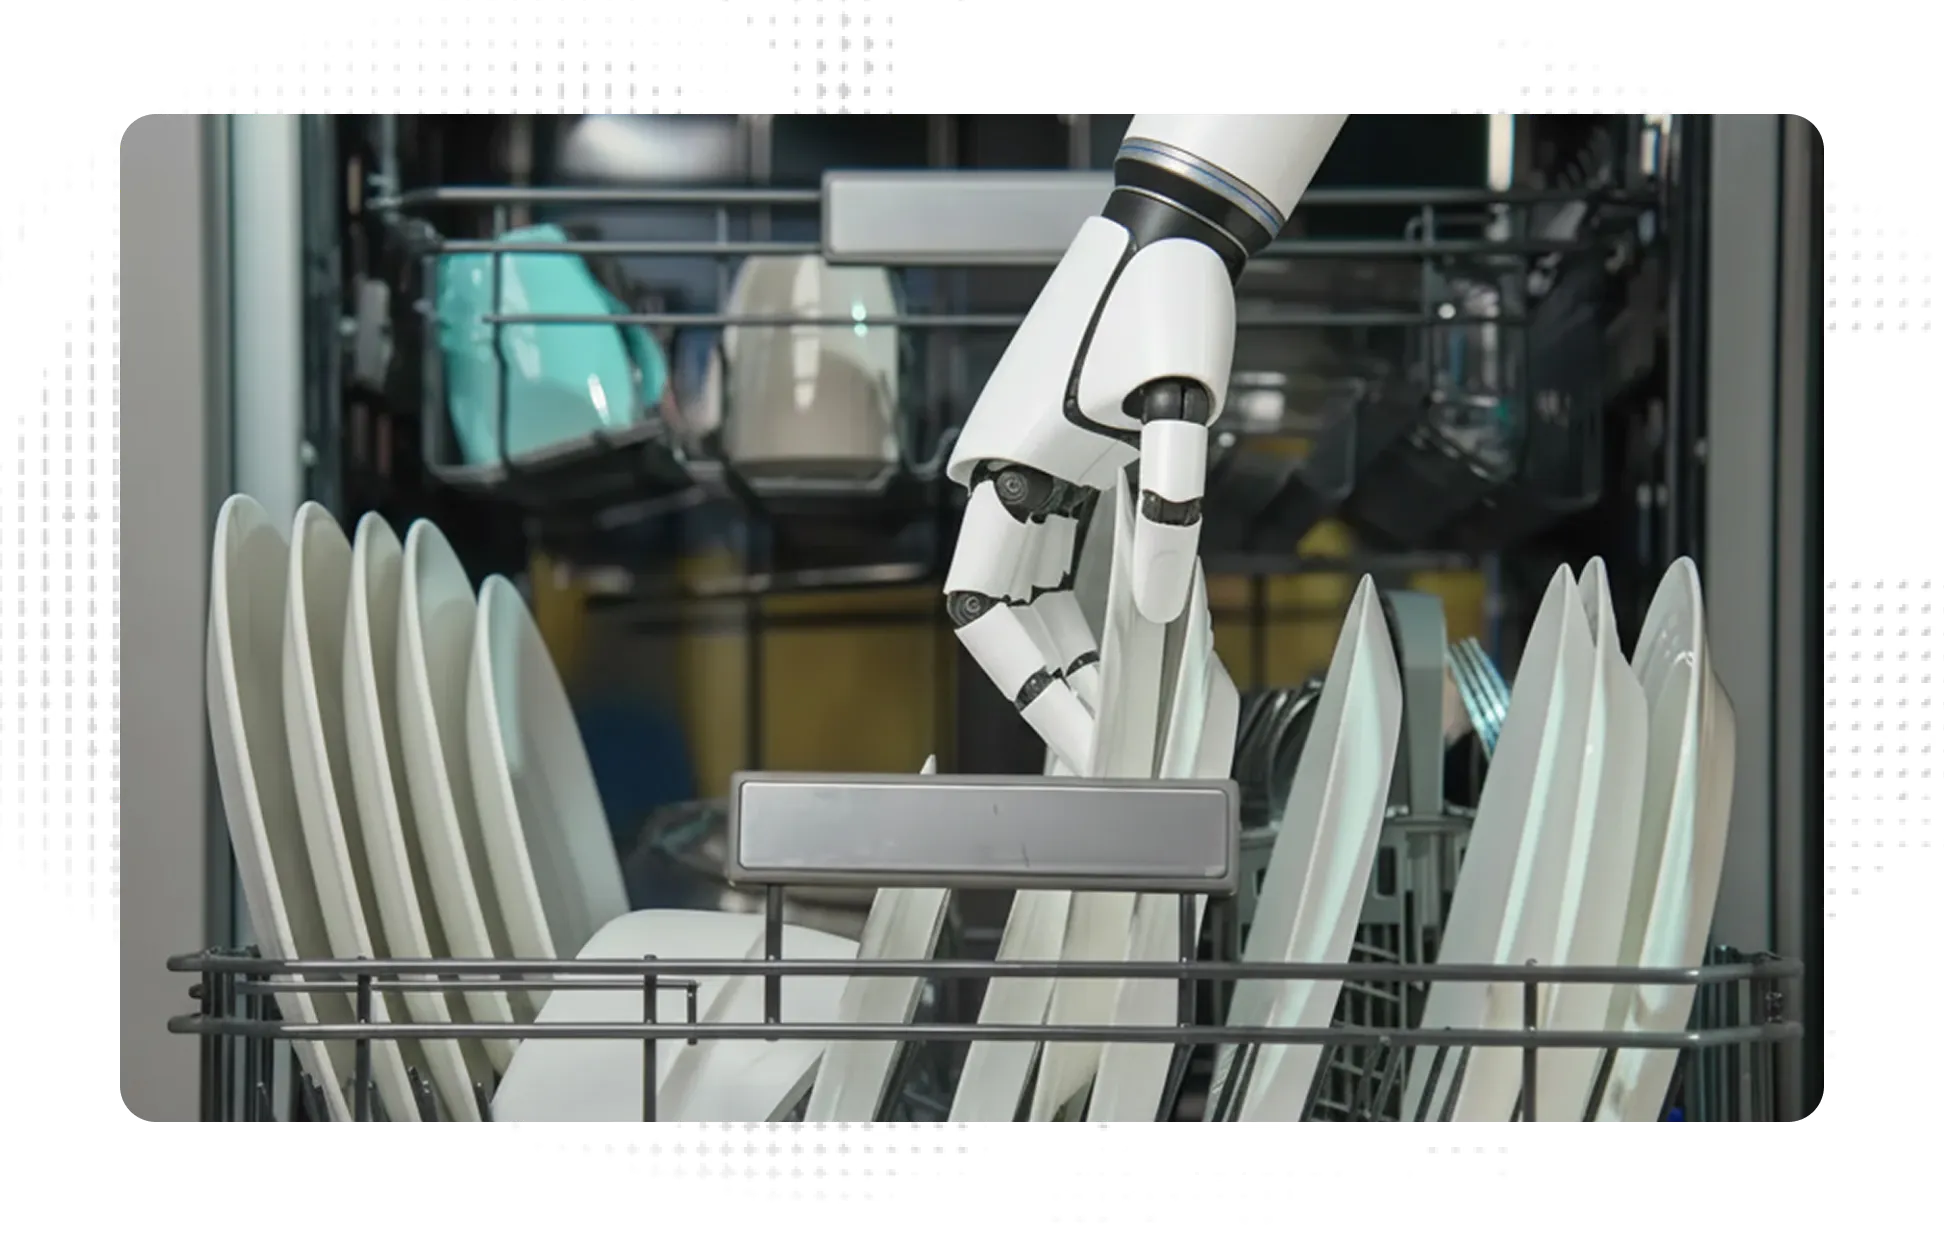
Operators run daily tasks custom to your robot - minimising cross-embodiment skill transfer - to produce the highest-fidelity training signal for your deployment config.
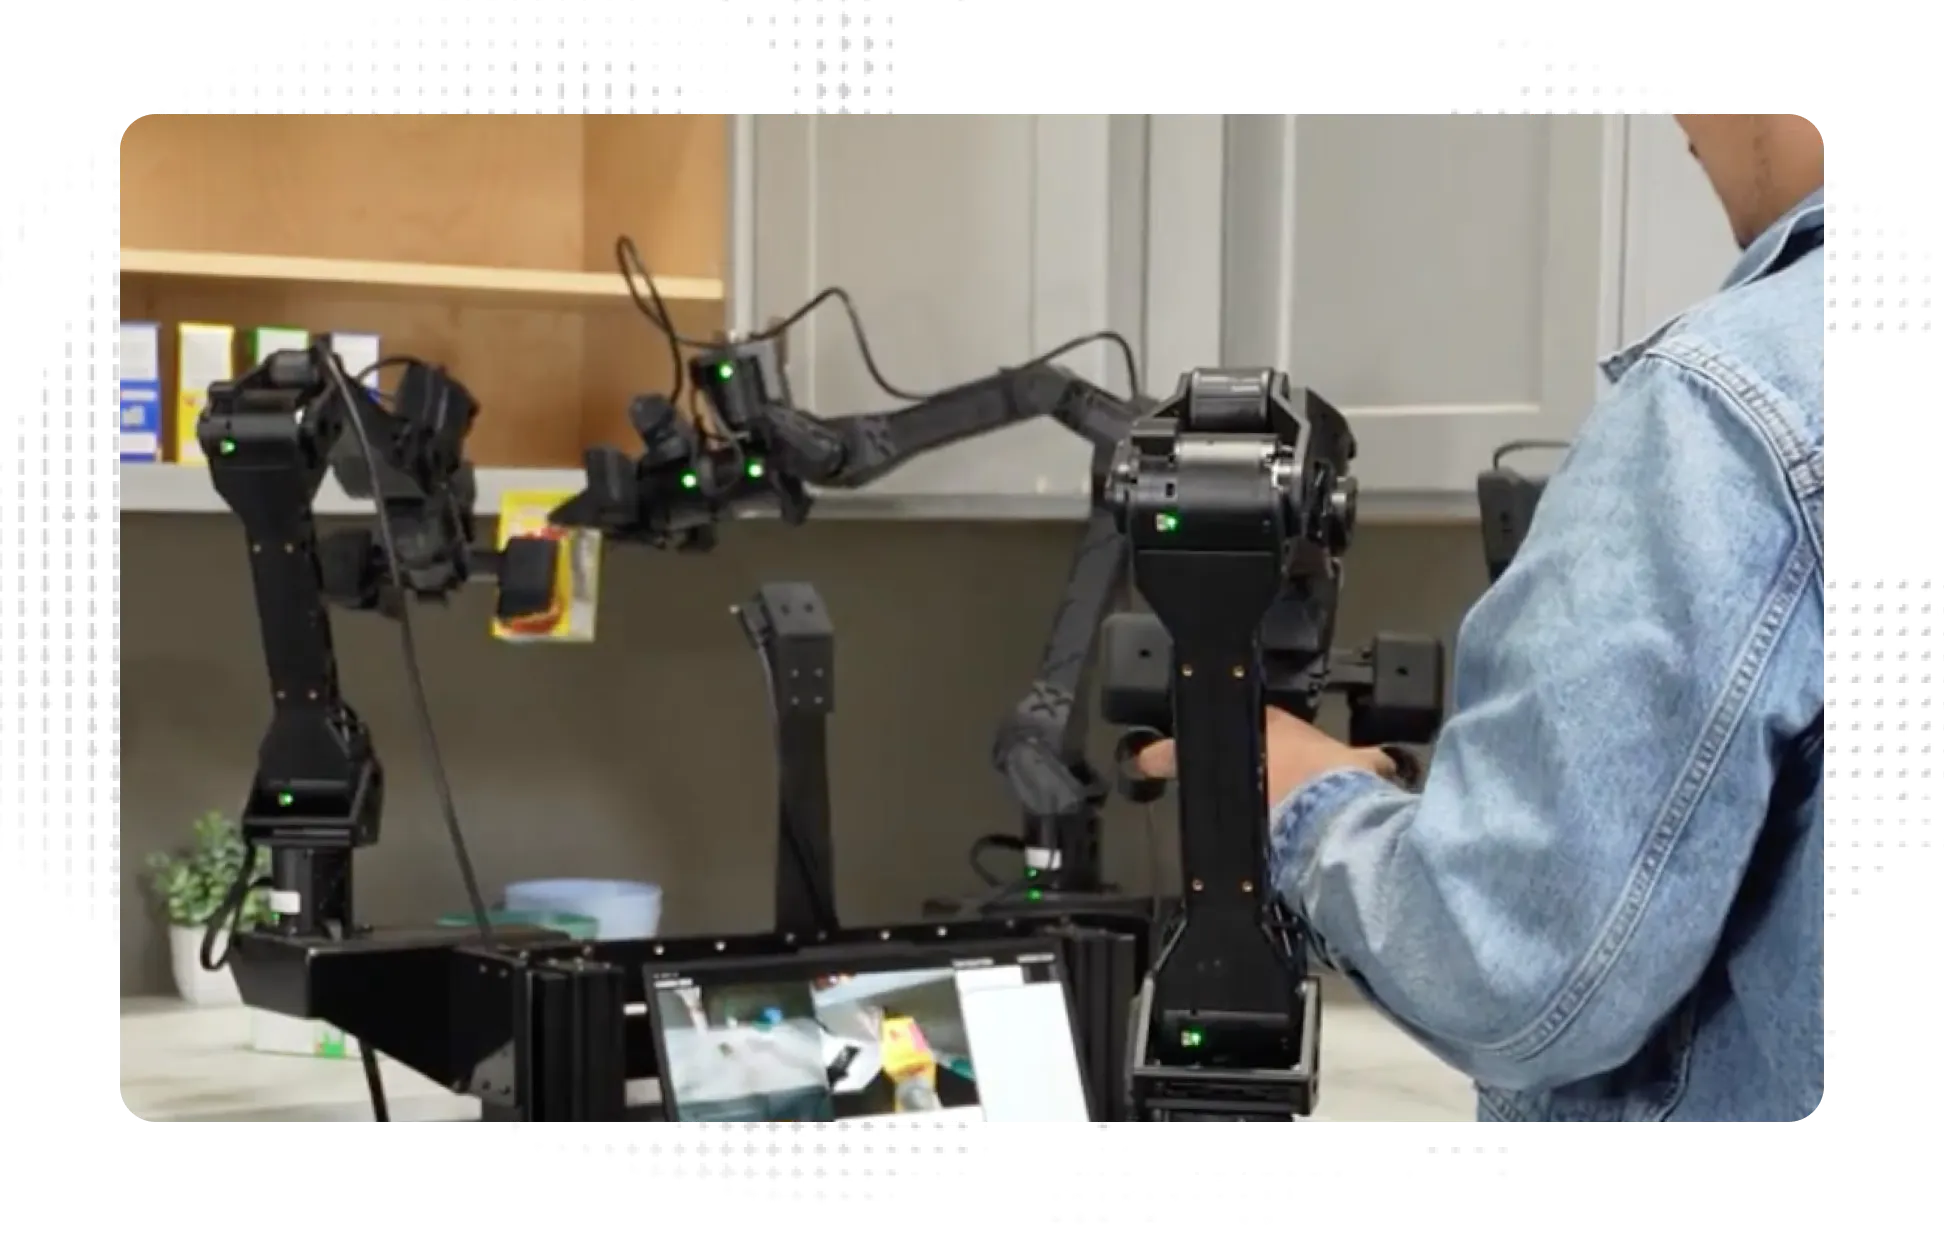
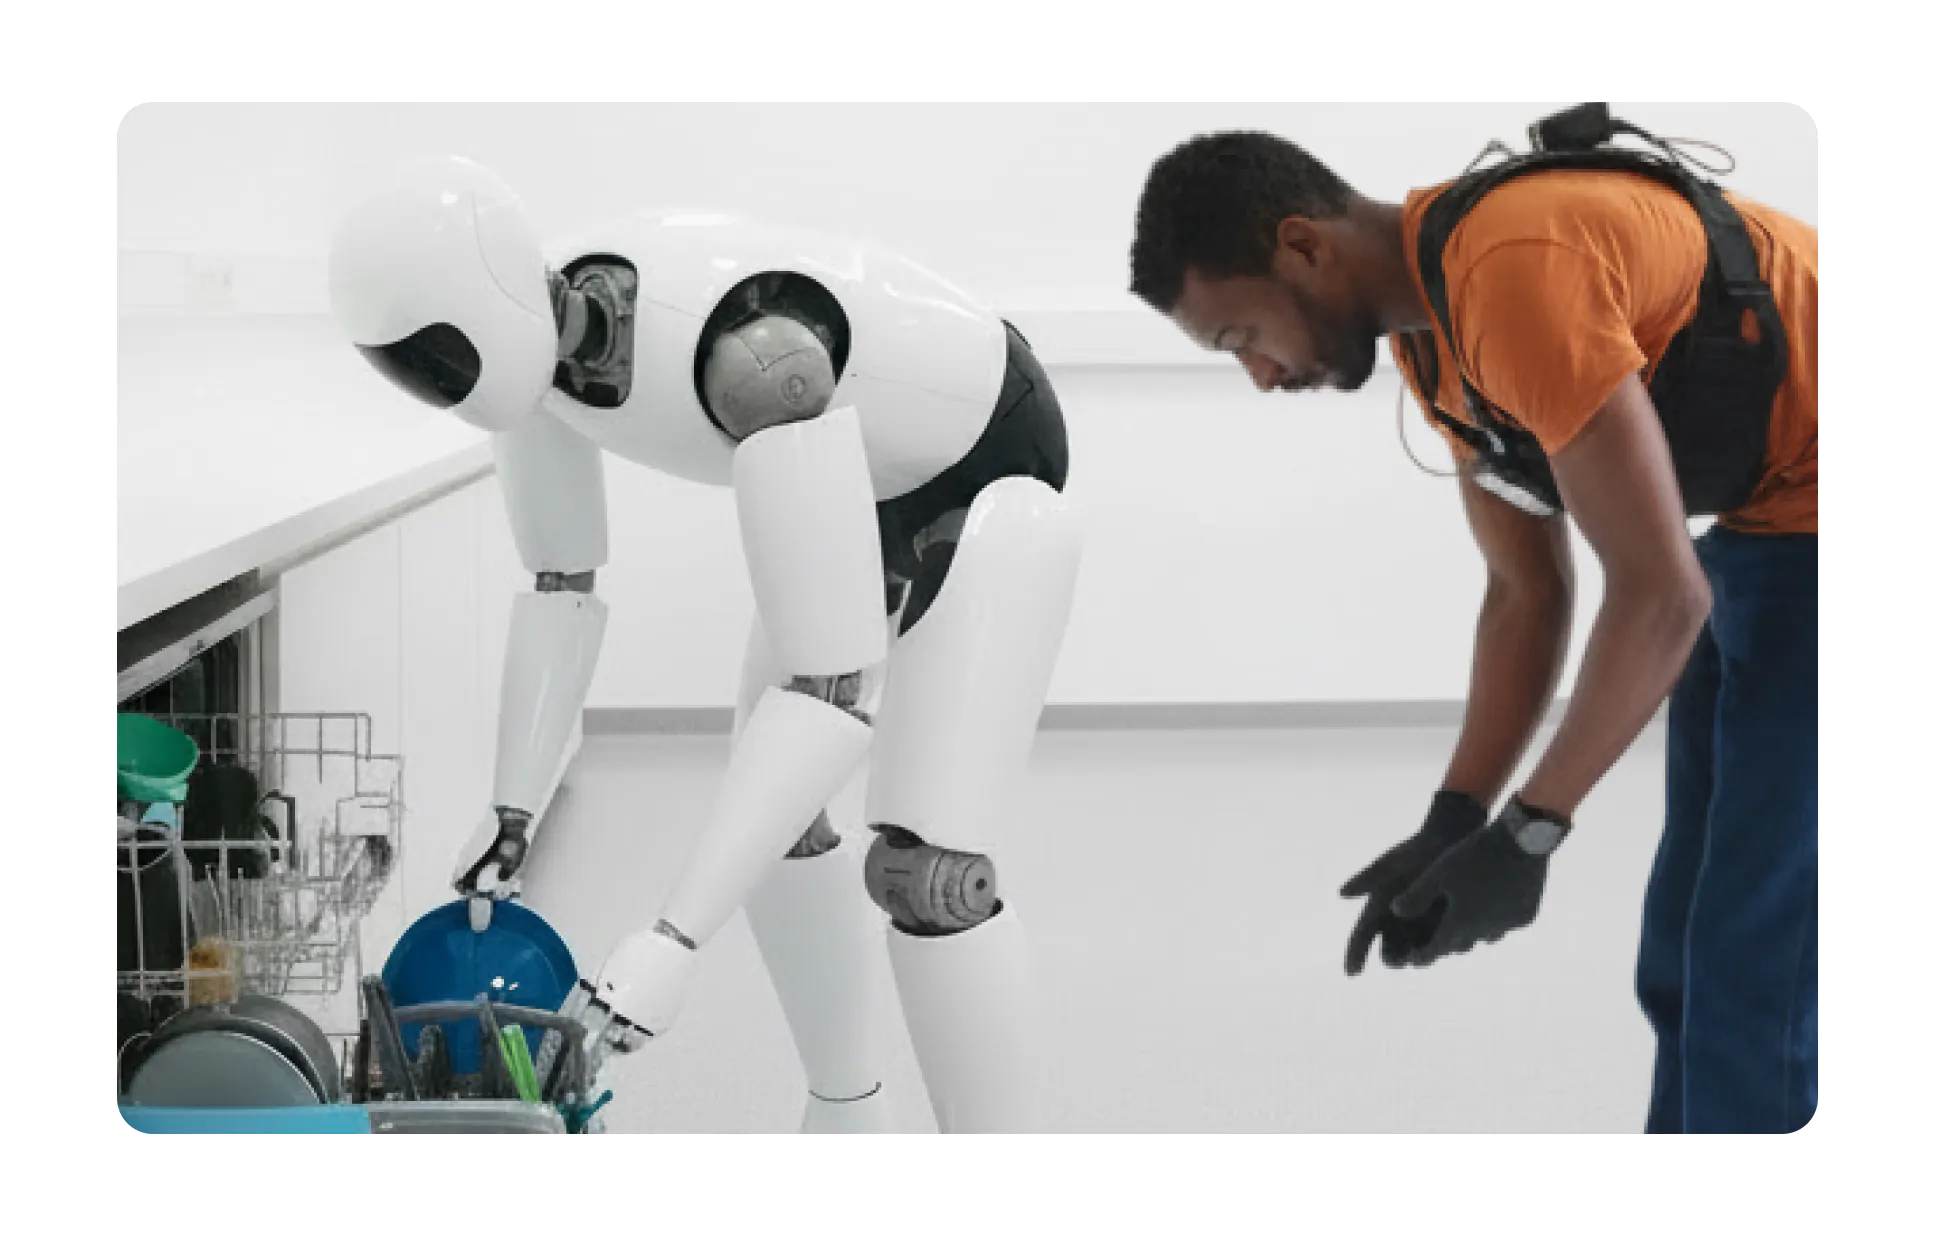
Leader/follower teleoperation machines operated by trained humans perform high-dexterity tasks - ideal for manipulation, grasping, and fine motor skill training.
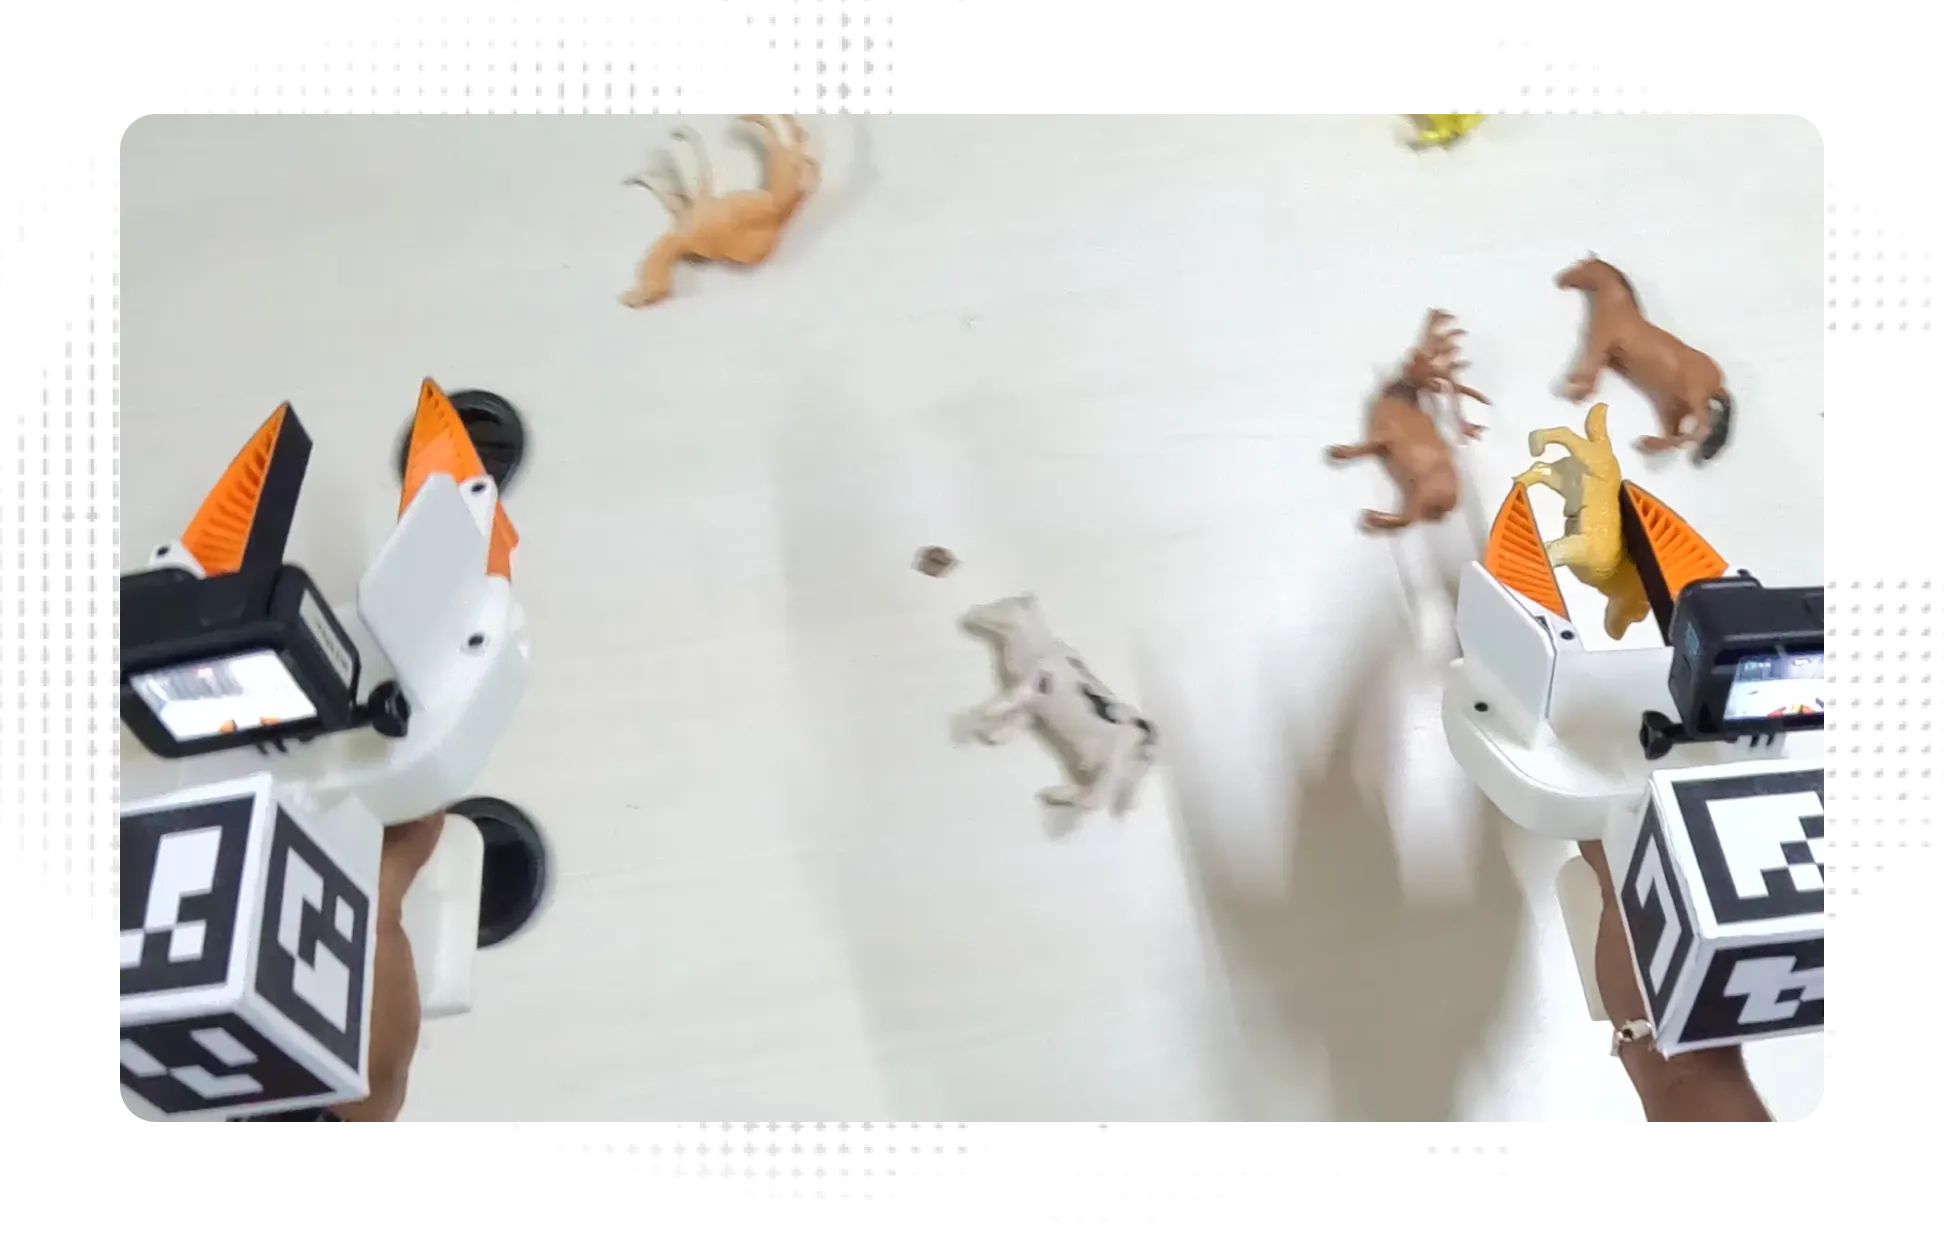
Handheld gripper systems capture robot-analogous manipulation data without a full robot - including standard UMI, multi-finger variants, and client-provided grippers.
“A big reason why we decided to partner with Encord was because of the quality bar we saw in doing POCs with a dozen companies.”
Devi Parikh
Co-Founder & Co-CEO of Yutori
Built around your training loop

We design the collection protocol with your team - task definitions, hardware configuration, and quality criteria in a controlled environment - before operators go into the field.

Encord has thousands of trained operators available across kitchens, warehouses, offices, vehicles, and industrial settings - fully scalable to your requirements.

Dedicated facilities with pods for kitchen, laundry and industrial environments - flexible LED lighting and teleops machinery, including stationary and mobile leader/follower arms.

Collected data flows directly into the Encord platform - ready to curate and route to human or model-assisted annotation.

Base kit includes RGB-D stereo depth cameras with IMU and multi-camera sync, paired with UMI grippers. Higher frame rates & multi-finger capture available.

We capture failure modes through remote teleoperation, feeding back into the pipeline to update collection policies.
Ask our dedicated robotics team about your specific collection requirements.
Book a callAsk our dedicated robotics team about your specific collection requirements.
Book a callFour types: embodiment-specific data, teleoperation data, egocentric data, and UMI handheld gripper data, including multi-finger variants and customer-provided hardware.
Collection starts at Encord facilities, not in the field. Tasks, hardware setup, and quality criteria are defined with your team, then piloted in a controlled lab environment before scaling. Iteration happens before operators deploy, so cost and time aren't spent recollecting data that doesn't match your training objective.
Collection is designed backwards from training - every episode is classified, synchronised, and ready-to-use by default, and your data flows directly into the Encord platform.
Diversity is built into protocol design, environments, lighting, operators, embodiments, and task variations are specified upfront, not left to chance during collection. Encord operates across multiple geographies and embodiment configurations, with hardware vendor partnerships (including teleoperation arm and biometric sensor providers) to close specific gaps in your training set.
Encord already works with more than 300 AI teams building AI models for real-world environments. With Encord, you get access to an expert network of in-field operators, dedicated facilities in the Bay Area, and zero ingestion overhead through the Encord platform.